Specify the filled bags a palletising cell must handle, including variation and the way they arrive. Compare the handling concept, required cycle and recovery procedure using representative bags rather than a nominal production rate alone.
Speak directly with Oxford Industrial Automation about robotic palletising of filled bags.
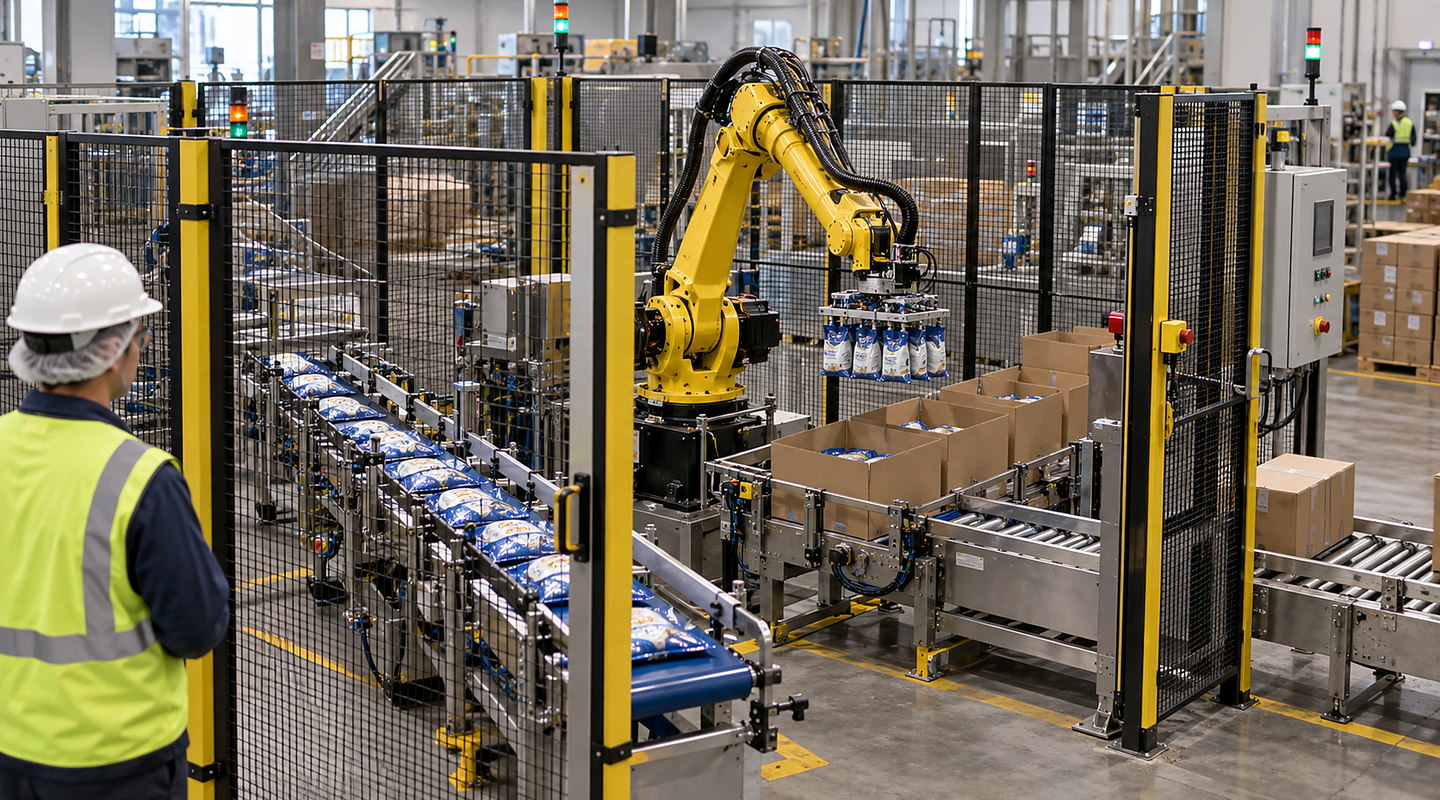
Illustrative robot case-packing line.
Quick answer
Which robot and gripper suit our filled bags and pallet patterns?
Trial filled bags at their actual weight, shape and surface condition. Compare how the proposed gripper picks, transfers and releases them in each pallet layer, including the bottom and final layers. The brief should include bag arrival spacing, pallet dimensions, stack height and the procedure for damaged bags or interrupted cycles.
Illustrative robot case-packing line.
Six useful questions
Describe what you need from bag palletising robots before choosing a solution
For repeatable production using robotic palletising of filled bags, share the normal condition, realistic range and difficult cases the finished system must handle.
Question 1
Part, Product and Process Variation for Robotic Palletising of Filled Bags
List filled-bag weights, dimensions, materials and closure styles, including how the shape and surface condition vary. Supply representative normal and difficult bags so the handling trial reflects the range your cell must accept.
Question 2
Arrival Pattern and Presentation
Record bag orientation, spacing and arrival variation at the pick point, including the shortest gaps and interrupted supply. Show how the bags reach the proposed cell so the handling sequence can be reviewed against the actual infeed.
Question 3
Required Cycle and Production Pattern
Record the bag arrival pattern and required output together. Review pickup, transfer and release across the agreed pallet layers, including interrupted supply and recovery, rather than using robot speed as the complete cycle.
Question 4
Tooling, Sensing and Process Interfaces
Show the filled bags, pick position and pallet layout for the handling trial. Define the connection between bag delivery and the cell, including arrival signals, operating modes and the conditions that stop or restart the process.
Question 5
Operator Access, Recovery and Changeover
Describe how operators replenish, clear, clean and maintain the cell. Include damaged bags, interrupted cycles and recipe changes in the agreed recovery and access review; do not assume automatic handling is safe without an application assessment.
Two useful starting points for bag palletising robots
The right choice changes with part, product and process variation for robotic palletising of filled bags, arrival pattern and presentation, your line layout and required results.
Your route from an initial enquiry to a working solution
You can review decisions about operator access, recovery and changeover and run-off criteria and production evidence at each stage.
01
Observe the Current Process and Collect Representative Samples
Share representative parts, process observations and cycle data, including the normal range for part, product and process variation for robotic palletising of filled bags and the difficult arrival pattern and presentation cases.
02
Prove Handling and Process Risks in a Focused Feasibility Trial
Compare suitable methods and use focused trials to show how each option performs against required cycle and production pattern.
03
Design and Build the Complete Guarded Cell
Connect the equipment to your line, services and controls while resolving tooling, sensing and process interfaces for day-to-day operation.
04
Run Agreed Scenarios and Support Production Ramp-Up
Confirm operator access, recovery and changeover, then complete and record run-off criteria and production evidence before your operating team takes over.
Important limits
Know what needs a separate check
Cycle time depends on the complete process rather than robot speed alone.
Part presentation, tolerances and recovery cases must be included in feasibility work.
Collaborative operation or automatic handling cannot be assumed safe without an application assessment.
Your final solution for robotic palletising of filled bags must reflect the law, current standards and site-specific risks that apply to your installation.